EV3 Drone Test Hardware
Hardware @ Zipline | Siemens NX, Altium, Systems Integration, Test Engineering, Modal Analysis
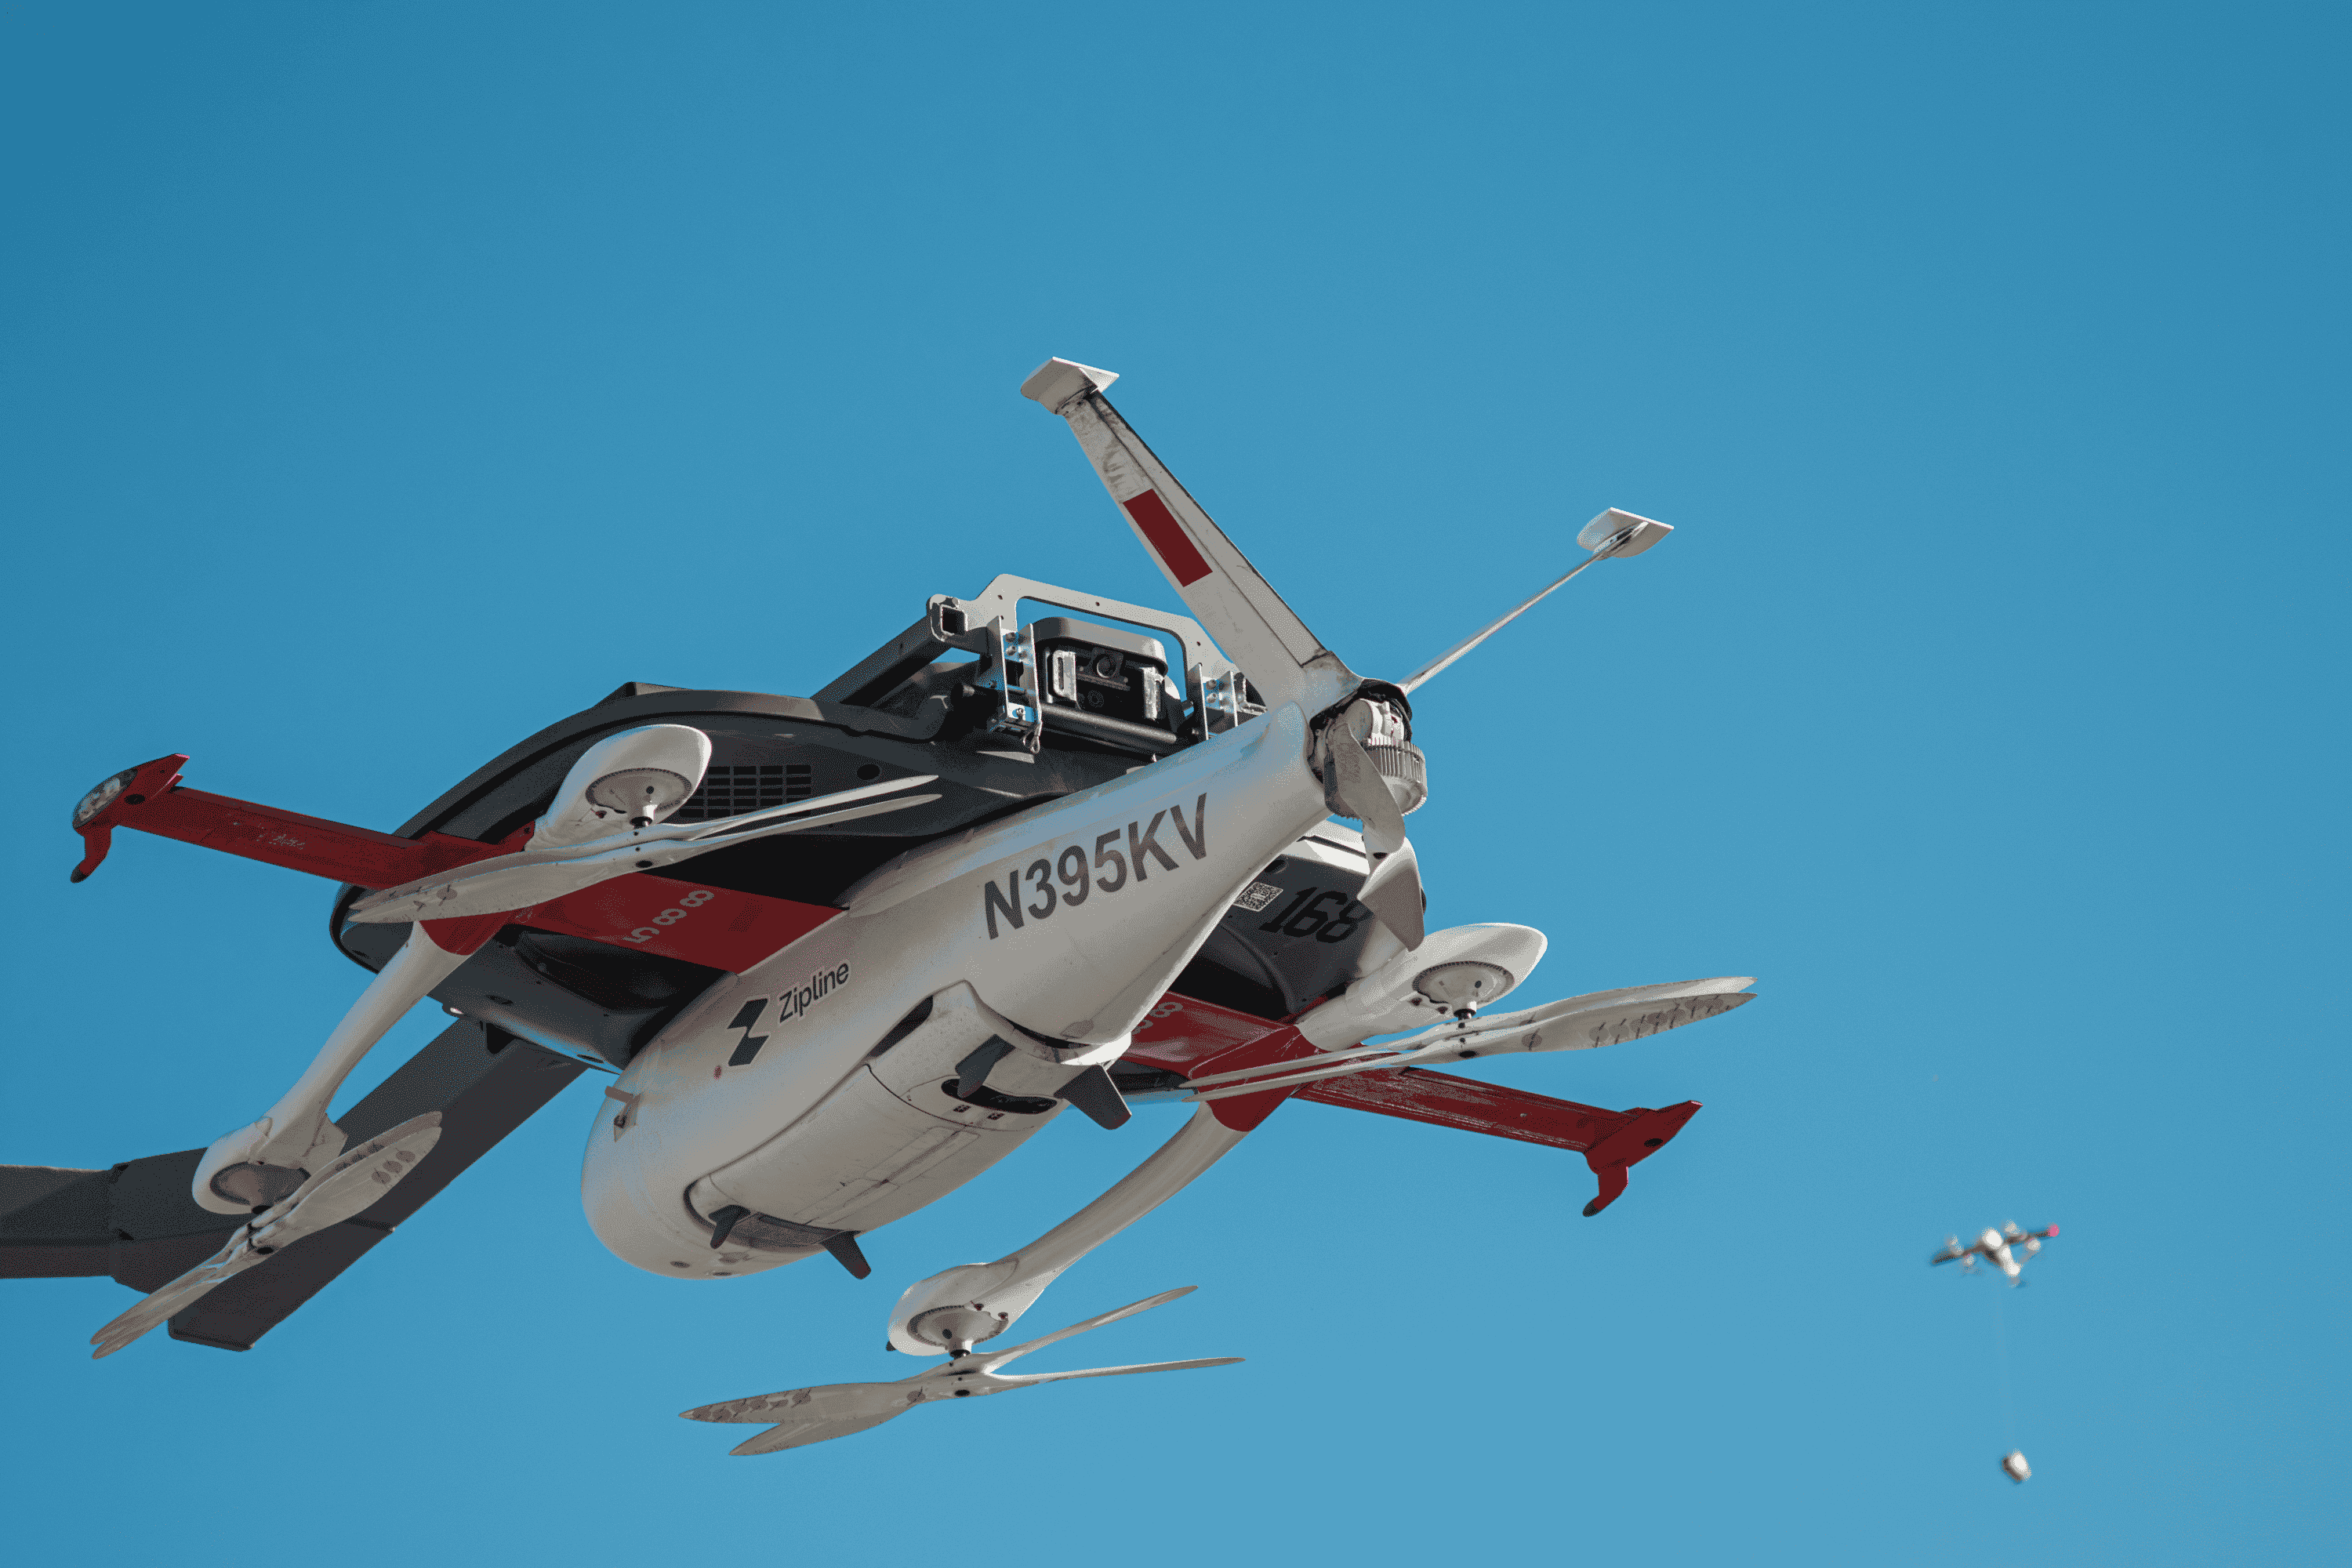
Owned multiple test legs for the EV3 drone during my first internship at Zipline, bringing up testers such as:
- An environmental chamber that holds 65 °C and 85% RH for 30 days with two drones and docks inside
- A test motor control PCB and 2 battery testing PCBs
- A 30,000 RPM motor rotor tester to validate magnet epoxy strength
- A full drone vibration fixture with a first mode beyond 500 Hz
Environmental chamber: Retrofitted a shipping container into an environmental chamber for accelerated testing of the full aircraft, droid and dock. Integrated an Arduino Opta and 8 RS-485 sensors to actuate heaters and misters through relay closed-loop control. Wrote multi-threaded C++ firmware for real-time control over RS-485 and a UART Python dashboard for data visualization, tuning duty cycles and tolerances to hold conditions for 30 days.
Vibration and battery testing: Owned an EV3 battery test campaign by designing 2 PCBs in Altium and a 2000 Hz first-mode vibration fixture in NX. Designed a full aircraft vibration fixture in NX for busbar testing, using modal analysis to push the first modal frequency beyond 500 Hz for launch-critical validation.
Motor rotor tester: Designed a tester in NX that spins rotors past 30,000 RPM through a 1:5 belt drive reduction to validate magnet epoxy strength.